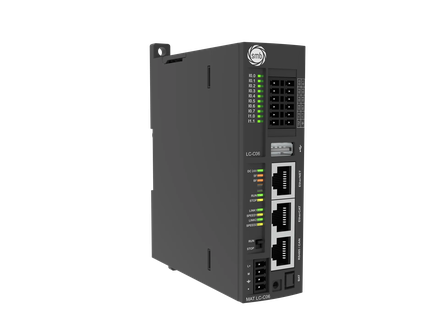
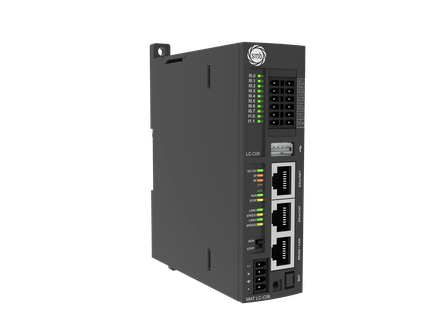
Representative view from a real series product record
Fieldbus
2 options
Digital Inputs
2 options
Supply Voltage
2 options
Series overview
What defines the series
What you choose between
2
GeneralCPU type
Multi-axis motion CPU (robotics and CNC capable)Single-axis motion CPU (SoftMotion)
ControlMotion control functions
SoftMotion; single-axis motion control, interpolation, electronic gearing and electronic camming instruction setSoftMotion; the single-axis motion control, interpolation, electronic gearing and camming instruction set, plus robot kinematics and a CNC function
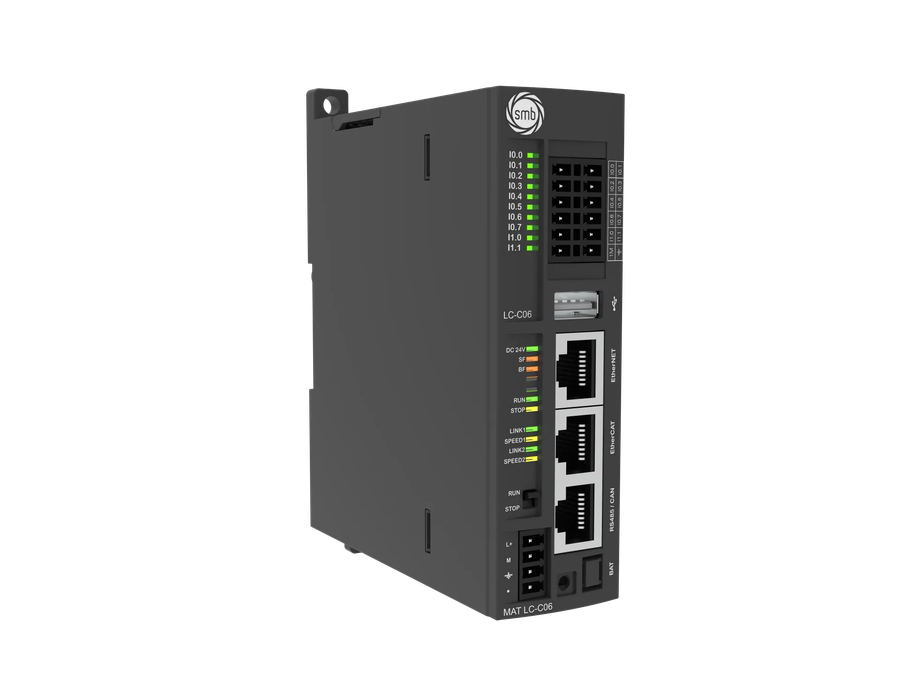
24 V supply (green), SF system fault (red), BF bus fault (red), RUN (green), STOP (yellow), Link1/Link2 (green), SPEED1/SPEED2 (yellow), I0.0-I1.1 input indicators (green)
GeneralLocal I/O expansion
Up to 4 racks; the main rack takes 11 modules (power supply, CPU, relay module and 8 signal modules), a slave rack takes 10
GeneralProgramming languages
IEC 61131-3: CFC / FBD / LD / IL / ST / SFC
GeneralProgramming software
CODESYS programming platform, version SP18
GeneralReal-time clock
Typically 112 hours of retention on power loss, at least one year with an external battery. Accuracy: less than 60 seconds drift per month
GeneralRemote I/O expansion
One master station; 32 CAN slave stations over CAN (277C); 128 EtherCAT slave modules with up to 8 signal modules each
CANopen Manager auto-start, optional slave polling, slave start-up, NMT, sync producing and consuming, heartbeat generation and enable time creation
CommunicationCANopen port
1 × CAN; CANopen DS301 standard protocol (DS402 for motion control); one master drives up to 32 slave stations
CommunicationCANopen speed / distance
1000 kbit/s → 25 m; 800 → 50 m; 500 → 100 m; 250 → 250 m; 125 → 500 m; 50 → 1000 m; 20 → 2500 m
CommunicationEtherCAT functions
Distributed clock (DC) and redundancy configuration, start-up parameter configuration, PDO parameter and mapping configuration, bus cycle time, and start-up vendor/product identity checking
CommunicationEtherCAT port
1 × EtherCAT, 100 Mbps adaptive, 100 m direct connection; 128 EtherCAT slave stations per master
CommunicationEthernet port
1 × Ethernet, 10/100 Mbps adaptive, UDP_PPI protocol; 100 m direct connection per cable; 16 UDP_PPI and 32 TCP connections
Supply reverse-connection protection and surge absorption; communication port lightning protection
Six interfaces on one CPU
EtherCAT, CANopen, Ethernet, RS-485/Modbus, USB and OPC UA on one processor, so the motion network, the field devices and the reporting link upstream need no separate gateway.
CODESYS and PLCopen DS402
The CODESYS V3.5 platform with the PLCopen DS402 motion library, SoftMotion and CNC, so the axis program is written with standard function blocks rather than a drive-specific language.
Integrated 500 kHz counters
Ten integrated digital inputs and six 500 kHz counter channels on the CPU itself, so a high-speed encoder or flow counter needs no additional module.
Recorded catalogue features
1 GHz CPUCODESYS-basedReal-time Linux32 MB program and data memory64 KB retentive memoryExpandable I/OExternal battery support for real-time clock1.5 GHz CPU