

Control and software
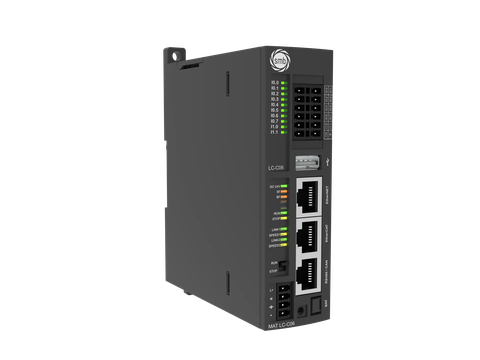
CODESYS-based CPUs, I/O and system modules.
One controller, one engineering environment, three fieldbuses. Follow the map to see which SMB series and product codes sit behind every block.
The coloured lines are the networks: EtherCAT, CANopen, Modbus RTU, Ethernet, digital I/O and power/feedback.
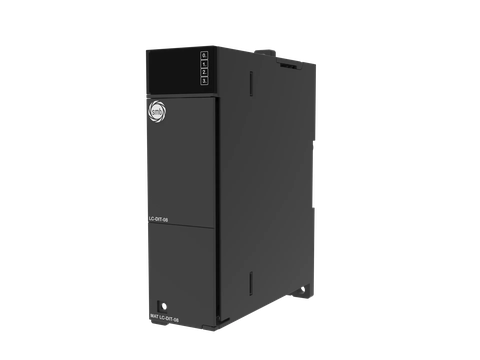 MAT-LC-DIT-08
PLC Digital Input Module — 8 × 24 V DC
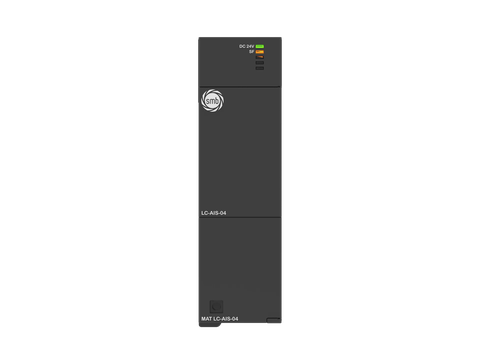 MAT-LC-DIT-16
PLC Digital Input Module — 16 × 24 V DC
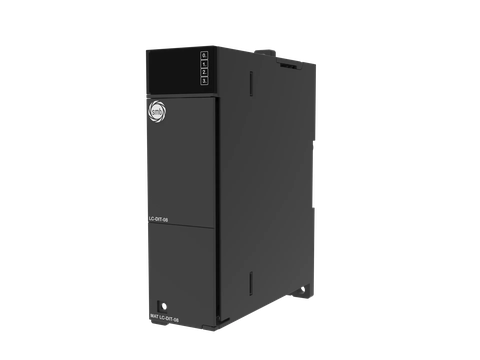 MAT-LC-AIS-04
PLC Analog Input Module — 4AI × 12-bit
 MAT-LC-AQS-04
PLC Analog Output Module — 4AQ × 12-bit
 MAT-LC-DQT-16
PLC Digital Output Module — 16 × 24 V DC
 MAT-LC-DQT-08
PLC Digital Output Module — 8 × 24 V DC
 MAT-LC-DQR-16
PLC Digital Output Module — 16 × Relay
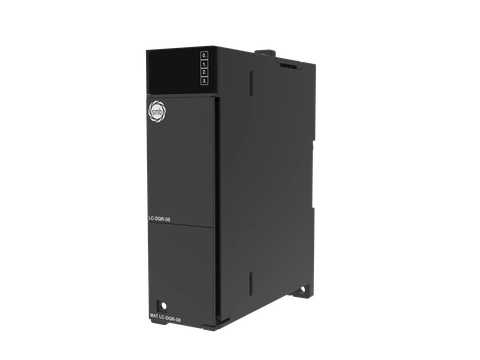 MAT-LC-DQR-08
PLC Digital Output Module — 8 × Relay
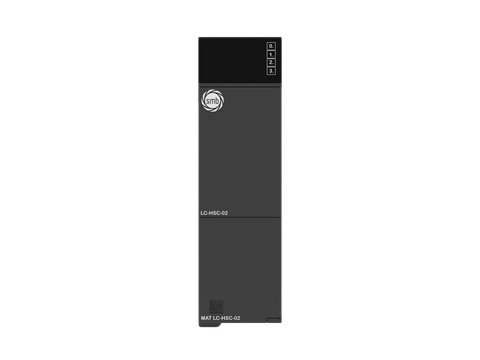 MAT-LC-HSC-02
Programmable Logic Controller Module High Speed Counter 2 x Differential/Single-Ended
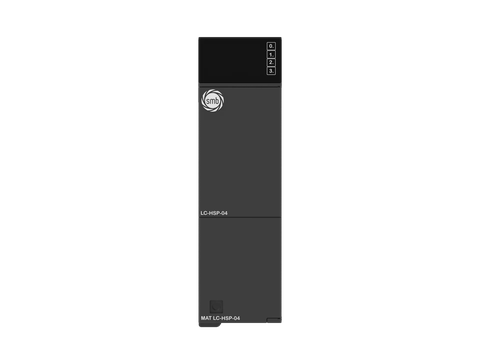 MAT-LC-HSP-04
Programmable Logic Controller Module High Speed Pulse 4 x Differential/Single-Ended
The industrial switch distributes Ethernet traffic between the controller, the operator panel and the engineering PC. It is part of the architecture, not part of the SMB catalogue.
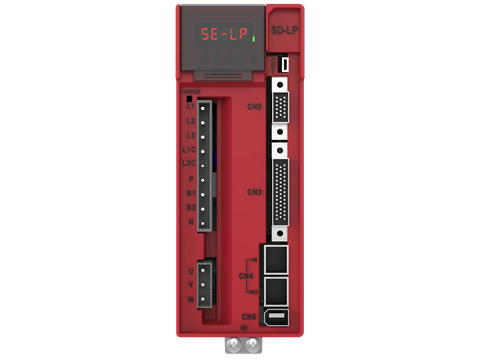
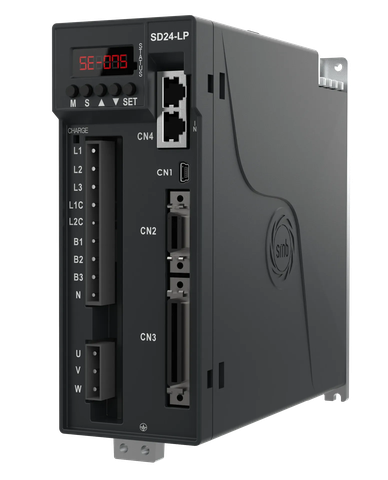 SD24-LP-04-D1-E
SD24-LP 400 W Single/Three-Phase 220 V AC EtherCAT Servo Drive
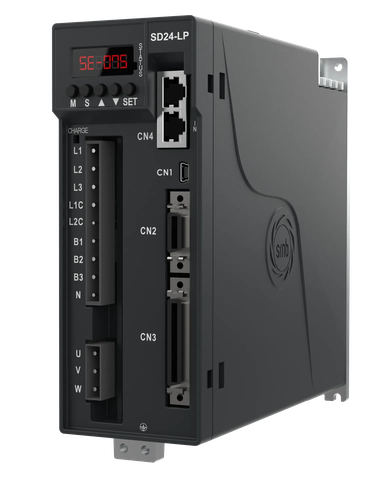 SD24-LP-07-D1-E
SD24-LP 750 W Single/Three-Phase 220 V AC EtherCAT Servo Drive
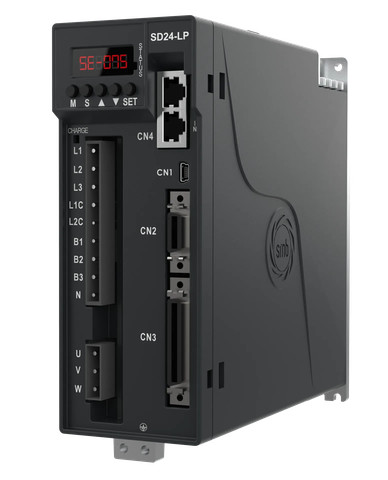 SD24-LP-10-D1-E
SD24-LP 1 kW Single/Three-Phase 220 V AC EtherCAT Servo Drive
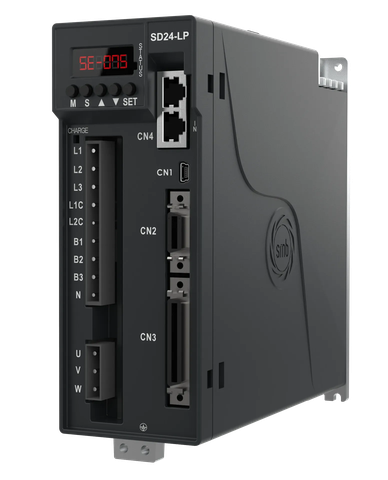 SD24-LP-15-D1-E
SD24-LP 1.5 kW Single/Three-Phase 220 V AC EtherCAT Servo Drive
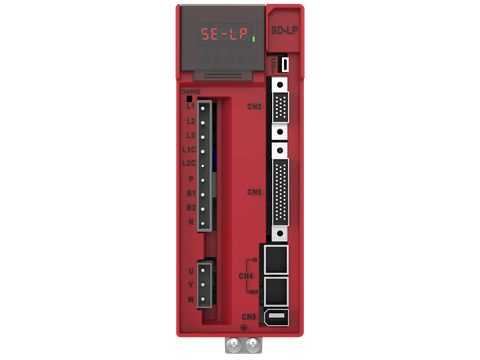 SD-LP-04-D1-E
SD-LP 400 W Single/Three-Phase 220 V AC EtherCAT Servo Drive
 SD-LP-07-D1-E
SD-LP 750 W Single/Three-Phase 220 V AC EtherCAT Servo Drive
 SD-LP-10-D1-E
SD-LP 1 kW Single/Three-Phase 220 V AC EtherCAT Servo Drive
 SD-LP-15-D1-E
SD-LP 1.5 kW Single/Three-Phase 220 V AC EtherCAT Servo Drive
 MAT-SDU3-MP-300-D3-E
SDU3 Series 3 kW Three-Phase 380 V AC EtherCAT Servo Drive
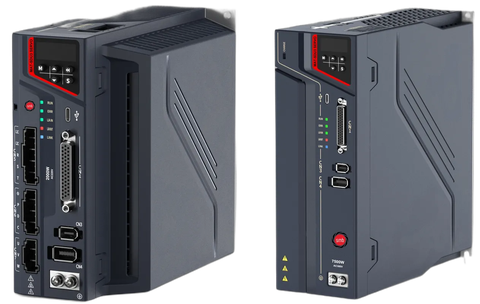 MAT-SDU3-MP-500-D3-E
SDU3 Series 5 kW Three-Phase 380 V AC EtherCAT Servo Drive
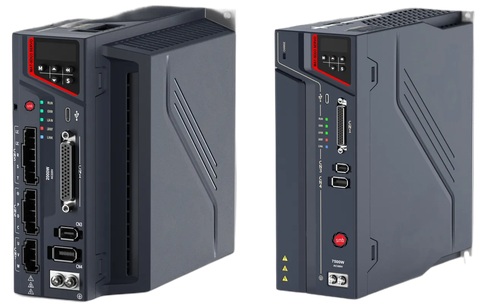 MAT-SDU3-MP-750-D3-E
SDU3 Series 7.5 kW Three-Phase 380 V AC EtherCAT Servo Drive
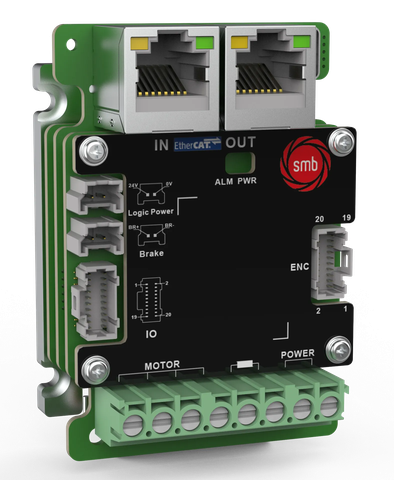 MAT-SDE3-LV-7020-NC-E
SDE3 Series 750 W EtherCAT Servo Drive — Open-frame
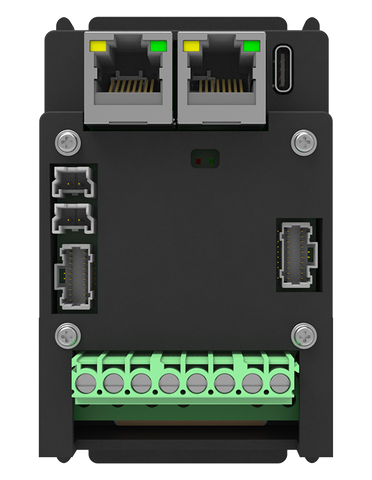 MAT-SDE3-LV-7020-CS-E
SDE3 Series 750 W EtherCAT Servo Drive — Enclosed
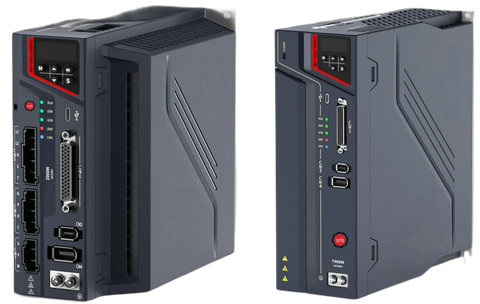 MAT-SDU3-MP-040-D3-E
SDU3 Series 400 W Three-Phase 380 V AC EtherCAT Servo Drive
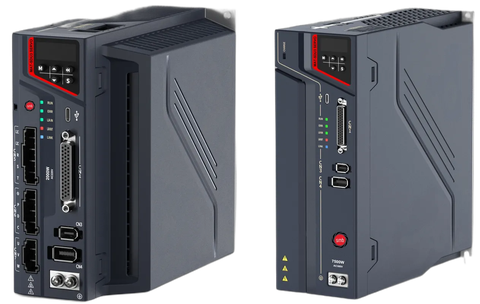 MAT-SDU3-MP-075-D3-E
SDU3 Series 750 W Three-Phase 380 V AC EtherCAT Servo Drive
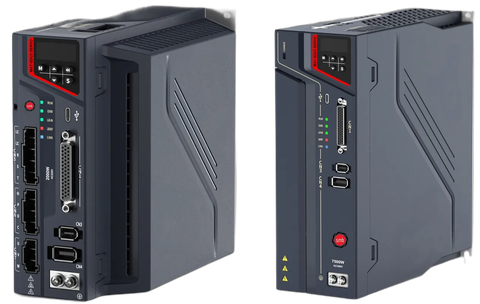 MAT-SDU3-MP-100-D3-E
SDU3 Series 1 kW Three-Phase 380 V AC EtherCAT Servo Drive
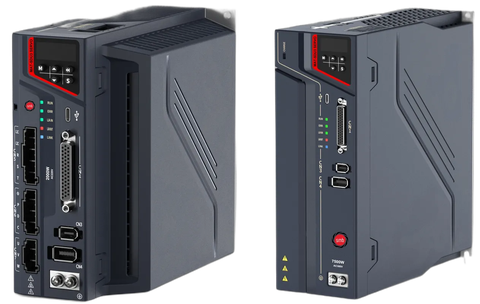 MAT-SDU3-MP-150-D3-E
SDU3 Series 1.5 kW Three-Phase 380 V AC EtherCAT Servo Drive
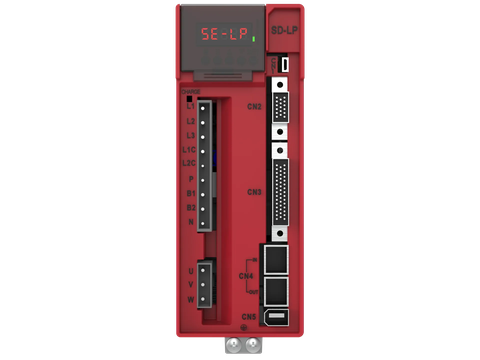 SD-LP-04-D1-C
SD-LP 400 W Single/Three-Phase 220 V AC CANopen Servo Drive
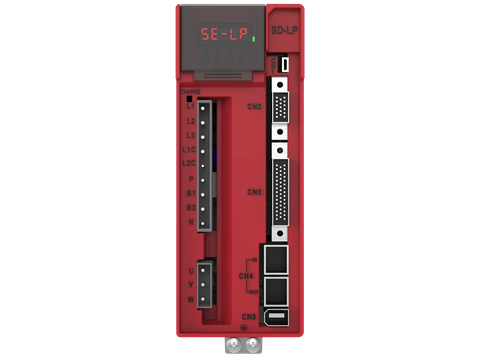 SD-LP-07-D1-C
SD-LP 750 W Single/Three-Phase 220 V AC CANopen Servo Drive
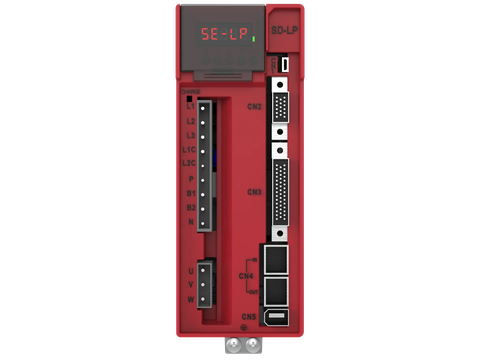 SD-LP-10-D1-C
SD-LP 1 kW Single/Three-Phase 220 V AC CANopen Servo Drive
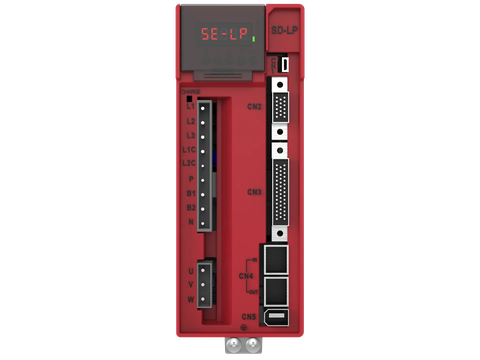 SD-LP-15-D1-C
SD-LP 1.5 kW Single/Three-Phase 220 V AC CANopen Servo Drive
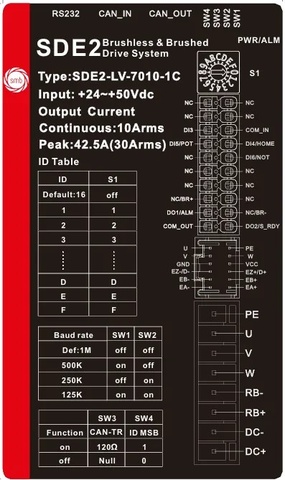
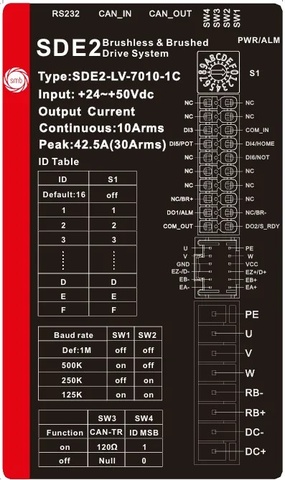 MAT-SDE2-LV-7010-CS-C
SDE2 Series 400 W CANopen Servo Drive — Enclosed
 MAT-SD2E2-LV-7030-CS-C
SD2E2 Series 2 × 1.2 kW Dual-axis CANopen Servo Drive — Enclosed
SMB controllers are programmed in CODESYS: the IEC 61131-3 languages, integrated motion and a single project covering both machine logic and the axes.
PLCopen Motion Control function blocks give every axis the same standard interface, so proven machine code carries over from one project to the next.
SMB servo drives implement the CiA 402 drive profile: the same state machine and the same operating modes over EtherCAT and over CANopen.
CODESYS-based CPUs, I/O and system modules.
Panels, teach pendant and Panel PC.
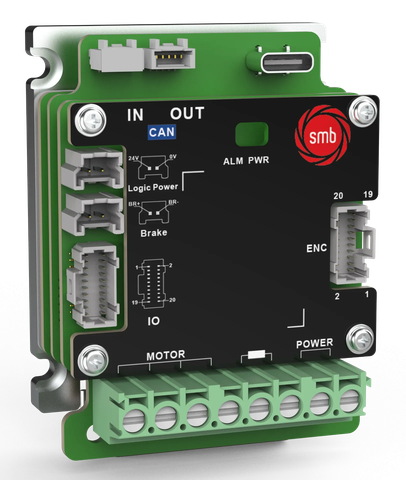
EtherCAT, CANopen and Modbus RTU servo drives.
Servo motors and sensors.
Power and encoder cables.
SD24-LP · SDU3 · SDE3
CANopen
A moderate number of independent axes, mobile systems
SD-LP · SDE2 / SD2E2
Modbus RTU
Parameter access, monitoring, simple commands
SD-LP
Pulse / direction
Quick commissioning from existing PLC pulse outputs
SD-LP
Analog ±10 V
External position loop, torque-controlled applications
SD-LP
Synchronised multi-axis control for contour accuracy at cutting speed.
Smooth, precise pointing for cameras, sensors and optical payloads.
Quiet, efficient low-voltage traction running from a battery.
Keep stations phase-locked electronically instead of by a line shaft.
Synchronised, dynamic axes on six-degree-of-freedom platforms.
A gantry that stays in sync at cutting speed, for fast, clean cuts.
Safe holding on vertical loads, precise position and recovered energy.
Millisecond settling on short, frequent, fast moves.
Send us the axis count, the load and the cycle time. We will size the drives, the motors and the cables for you.
Request Quote